> For the complete documentation index, see [llms.txt](https://hacking-notes.jord4n.pro/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://hacking-notes.jord4n.pro/zh/hacking-tools/enumeration/ruview-wifi-sensing.md).

# RuView WiFi 感知

RuView WiFi 感知笔记，用于学习如何利用信道状态信息在无摄像头的情况下探测存在、移动、生命体征和房间活动。

[RuView](https://github.com/ruvnet/RuView) 是一个实验性的 WiFi 感知平台。它不使用摄像头，而是研究当有人在房间里移动、坐下、呼吸或走动时，WiFi 信号如何变化。

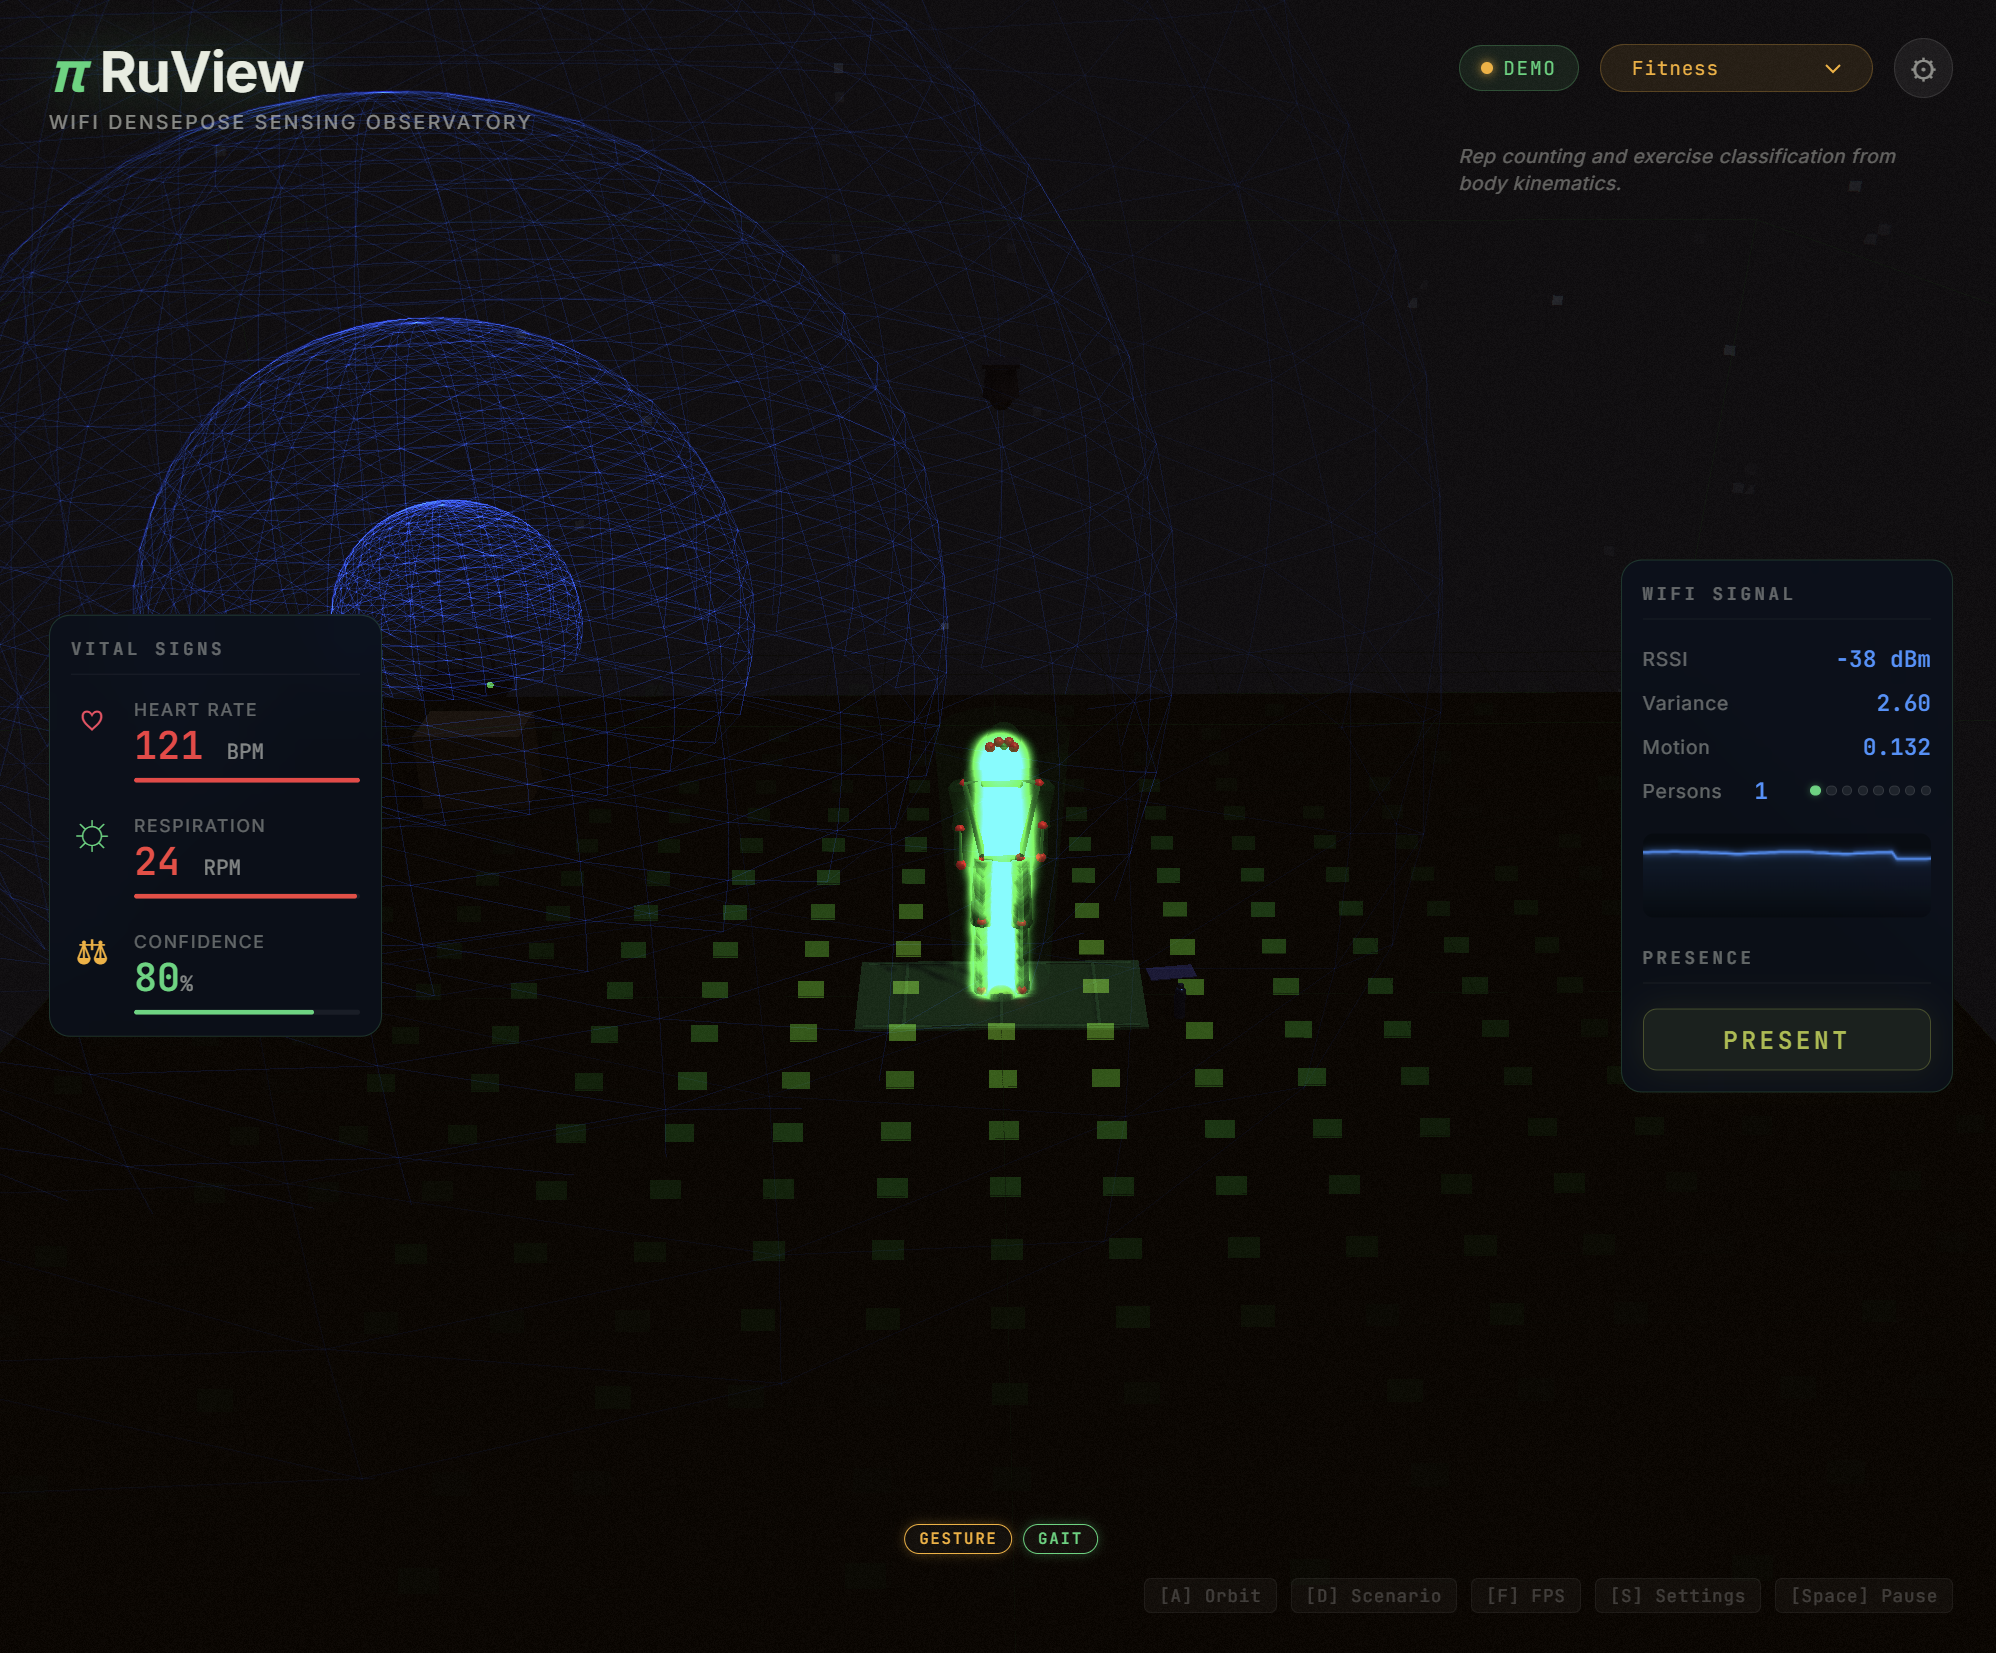
<figure><img src="https://raw.githubusercontent.com/ruvnet/RuView/main/assets/v2-screen.png" alt="RuView WiFi DensePose observatory showing a room sensing demo with vital signs and presence panels"><figcaption><p>来自官方仓库的 RuView Observatory 演示。</p></figcaption></figure>

{% hint style="info" %}
仅在授权实验室或人们知晓自己正被监测的空间中使用 RuView。除非你已独立验证，否则请将存在、姿态、跌倒和生命体征输出视为研究信号。
{% endhint %}

## 视觉演示与视频

在尝试硬件之前，先用这些可视化内容了解项目。从演示开始，然后将界面显示的内容与你自己的受控实验进行比较。

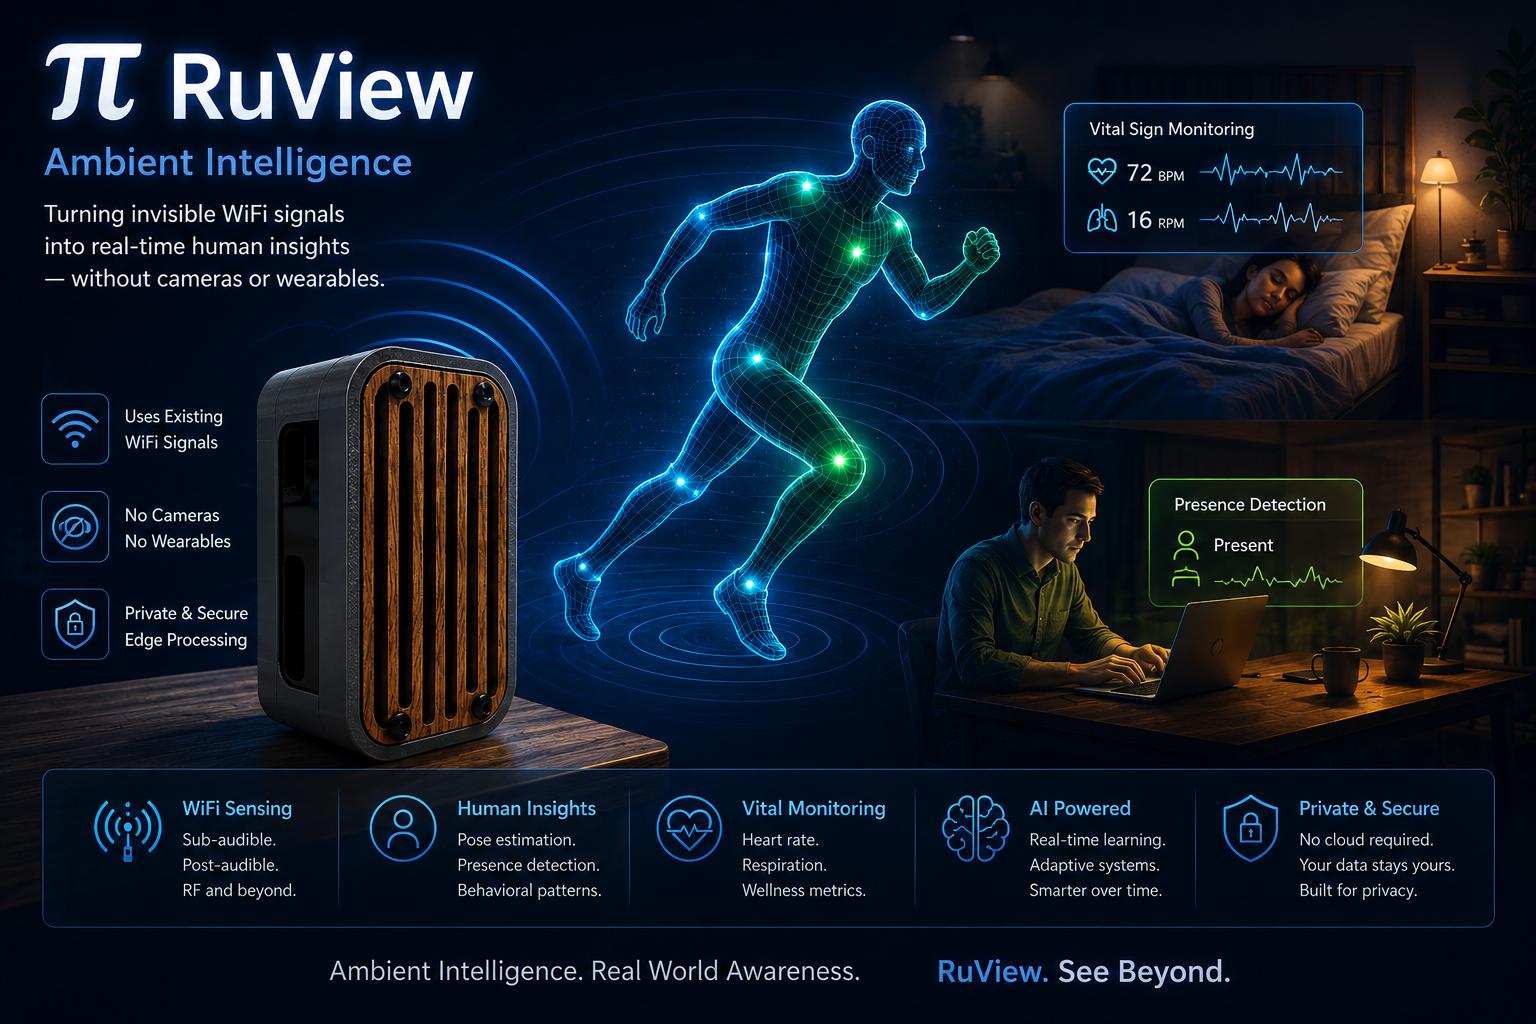
<figure><img src="https://raw.githubusercontent.com/ruvnet/RuView/main/assets/ruview-seed.png" alt="RuView overview graphic from the official repository"><figcaption><p>RuView 官方视觉概览。</p></figcaption></figure>

### 在线 Observatory

官方浏览器演示会循环展示多种场景，例如空房间、生命体征、多人员跟踪、跌倒检测、睡眠监测、入侵检测以及搜索与救援。

{% embed url="<https://ruvnet.github.io/RuView/>" %}

### 姿态融合演示

此演示有助于理解视觉姿态数据与 WiFi CSI 解析之间的区别。请将其作为概念展示，而不是证明每个房间都能以相同方式工作。

{% embed url="<https://ruvnet.github.io/RuView/pose-fusion.html>" %}

### 点云演示

点云演示有助于解释如何将感知输入转化为一个空间视图。

{% embed url="<https://ruvnet.github.io/RuView/pointcloud/>" %}

### 背景视频

这个视频并非 RuView 专属，但它对基于 WiFi 的 DensePose 背后的学术思想提供了一个简单的高层解释。

{% embed url="<https://www.youtube.com/watch?v=OhrQ0T6Yl9k>" %}

| 视觉                     | 需要关注什么                   |
| ---------------------- | ------------------------ |
| Observatory 演示         | 存在、移动、置信度、模拟生命体征、场景切换。   |
| 姿态融合                   | 类似姿态的输出如何可视化，以及为什么验证很重要。 |
| 点云                     | 感知如何变成空间表示。              |
| 来自 WiFi 的 DensePose 视频 | 基于 WiFi 的人体估计背后的研究背景。    |

## 它能做什么

RuView  ცდილ试图将 WiFi 信号变化转化为有用的房间级信息：

| 用例     | 通俗含义                            |
| ------ | ------------------------------- |
| 存在检测   | 房间里有人吗？                         |
| 运动检测   | 有人在走动、坐着还是移动吗？                  |
| 生命体征   | 从微小的信号变化中估计呼吸或心率趋势。             |
| 活动识别   | 识别重复模式，例如手势、睡眠、房间活动或可能的跌倒。      |
| 智能家居事件 | 将存在或活动状态暴露给 Home Assistant 等系统。 |
| 研究演示   | 可视化基于 WiFi 的姿态、点云和感知场景。         |

## 工作原理

WiFi 已经会在房间里反射。人体会轻微改变这些无线电路径。RuView 将这些变化视为 **信道状态信息** （CSI），清理信号，并将其发送给模型或简单规则来估计可能正在发生的事情。

简单流程：

```
WiFi 信号
  -> ESP32 或支持 CSI 的硬件
  -> CSI 流
  -> RuView 处理
  -> 存在、移动、生命体征或演示可视化
```

一个容易理解的方式是：摄像头看到的是像素；RuView 看到的是无线电反射中的微小变化。这使它在研究中很有用，但也会对房间布局、家具、墙壁、人数、天线位置和校准非常敏感。

## 你需要什么

| 目标          | 推荐配置                                                 |
| ----------- | ---------------------------------------------------- |
| 快速试用界面      | 带模拟数据的 Docker 演示。                                    |
| 学习 Python 包 | `pip install ruview` 或 `pip install wifi-densepose`. |
| 测试真实 CSI 采集 | 带有 RuView 固件的 ESP32-S3 或 ESP32-C6 开发板。               |
| 更好的房间覆盖     | 多个 ESP32 节点或一个小型网状网络。                                |
| 模型实验        | Hugging Face 模型包和本地数据集。                              |

## 快速 Docker 演示

这是最容易进行的首次测试，因为它不需要硬件。

```bash
docker pull ruvnet/wifi-densepose:latest
docker run -p 3000:3000 ruvnet/wifi-densepose:latest
```

打开：

```
http://localhost:3000
```

在购买或刷写硬件之前，先用这个模式了解仪表盘、场景和预期输出。

## Python 包

安装 Python 包：

```bash
pip install ruview
```

替代包名：

```bash
pip install wifi-densepose
```

为 WebSocket 和 MQTT 工作流安装可选客户端支持：

```bash
pip install "ruview[client]"
```

基础导入检查：

```python
from ruview import BreathingExtractor, HeartRateExtractor
```

## 预训练模型

RuView 在 Hugging Face 上发布了预训练的 WiFi 感知权重。将它们下载到本地：

```bash
pip install huggingface_hub
huggingface-cli download ruvnet/wifi-densepose-pretrained --local-dir models/wifi-densepose-pretrained
```

这些文件可用于学习、检查和实验。对于实时部署，请查看当前仓库说明，因为模型格式和服务器支持可能会变化。

## ESP32 硬件设置

对于真实的 CSI 感知，请使用能够暴露 WiFi 信道信息的 ESP32 硬件。README 强调 ESP32-S3 和 ESP32-C6 是实用选项。

典型的高层流程：

1. 构建或下载 ESP32 CSI 节点固件。
2. 将固件刷入开发板。
3. 配置 WiFi 凭据和目标服务器 IP。
4. 启动 RuView 感知服务器或桥接程序。
5. 打开仪表盘并进行一个小房间实验。

项目 README 中的刷写示例：

```bash
python -m esptool --chip esp32s3 --port COM9 --baud 460800 \
  write_flash 0x0 bootloader.bin 0x8000 partition-table.bin \
  0xf000 ota_data_initial.bin 0x20000 esp32-csi-node.bin
```

配置 WiFi：

```bash
python firmware/esp32-csi-node/provision.py --port COM9 \
  --ssid "YourWiFi" --password "secret" --target-ip 192.168.1.20
```

## 首次实验

在尝试姿态或生命体征之前，先从简单实验开始：

| 实验      | 记录什么          |
| ------- | ------------- |
| 空房间     | 无人时的基线信号。     |
| 一人进入    | 存在变化和置信度。     |
| 穿过房间走动  | 运动信号和时序。      |
| 静坐不动    | 误报和稳定性。       |
| 门打开但没有人 | 环境噪声检查。       |
| 两人进入    | 人数和运动是否变得不稳定。 |

良好的记录会让结果更有用：

* 房间布局。
* 传感器位置。
* WiFi 信道。
* 人数。
* 节点之间的墙壁或家具。
* 重复的正例和负例测试。

## 实用命令

运行模拟演示：

```bash
docker run -p 3000:3000 ruvnet/wifi-densepose:latest
```

下载模型文件：

```bash
huggingface-cli download ruvnet/wifi-densepose-pretrained --local-dir models/wifi-densepose-pretrained
```

从项目固件文件夹构建 ESP32-C6 固件：

```bash
cd firmware/esp32-csi-node
idf.py set-target esp32c6
idf.py build
idf.py -p COM6 flash
```

从仓库脚本运行实时 RF 房间扫描：

```bash
node scripts/rf-scan.js --port 5006
```

## 适用于何时

RuView 很适合用于：

* 无线与 IoT 研究。
* 无摄像头感知的隐私评估。
* 智能家居存在感实验。
* 理解 WiFi 如何变成传感器。
* CSI、运动和 RF 指纹的实验室演示。

它不能替代：

* 经过认证的医疗设备。
* 单独作为可靠的安全警报。
* 类似摄像头级别的身份识别或姿态系统。
* 适当的物理安全验证。

## 验证检查清单

在信任任何输出之前：

1. 确认演示或服务器正在运行。
2. 确认硬件输出的是 CSI，而不仅仅是 RSSI。
3. 记录空房间基线。
4. 每个测试重复多次。
5. 运行不应触发检测的负向测试。
6. 将生命体征或安全事件与独立参考进行比较。
7. 记录失败，而不仅仅是成功截图。

## 参考资料

* [RuView 官方仓库](https://github.com/ruvnet/RuView)
* [RuView 用户指南](https://github.com/ruvnet/RuView/blob/main/docs/user-guide.md)
* [RuView 在线 Observatory 演示](https://ruvnet.github.io/RuView/)
* [RuView 在 Hugging Face 上的预训练模型](https://huggingface.co/ruvnet/wifi-densepose-pretrained)
* [RuView 运动捕捉指南](https://ruview.blog/ruview-motion-capture/)


---

# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.

## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.

Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:

```
GET https://hacking-notes.jord4n.pro/zh/hacking-tools/enumeration/ruview-wifi-sensing.md?ask=<question>&goal=<user_goal>
```

`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.

The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.

Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.